Basis, Coordinates and Dimension of Vector Spaces
Before we formally define the basis of a vector space, we examine examples of bases in two-dimensional space from physics and analytical geometry to build foundational intuition.
Definition of a Basis for 2-Dimensional Space Using Rectangular Axes
We first discuss what we know about vectors in a two-dimensional space, as used in physics and analytical geometry. The graph below shows a point \( P \), the orthogonal unit vectors \( \mathbf{i} \) and \( \mathbf{j} \), and the vector \( \mathbf{OP} \).
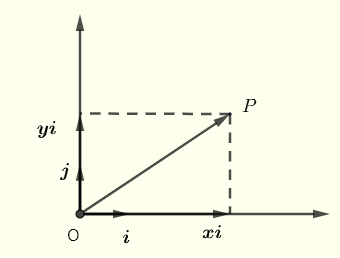
Vector \( \mathbf{OP} \) may be expressed as a linear combination of the unit vectors \( \mathbf{i} \) and \( \mathbf{j} \):
\( \mathbf{OP} = x\,\mathbf{i} + y\,\mathbf{j} \)
Here \( x \) and \( y \) are the coordinates of \( \mathbf{OP} \) relative to the basis \( \{ \mathbf{i}, \mathbf{j} \} \).
Using vector addition via a parallelogram, there is a unique way to combine multiples of \( \mathbf{i} \) and \( \mathbf{j} \) to obtain \( \mathbf{OP} \). Every vector in the plane has a unique representation as \( x\mathbf{i} + y\mathbf{j} \), provided \( \mathbf{i} \) and \( \mathbf{j} \) are not parallel (equivalently, linearly independent). Since every vector in the plane can be so expressed, the pair \( \{ \mathbf{i}, \mathbf{j} \} \) forms a basis for the 2-dimensional space.
Generalizing the Definition of a Basis for a 2-Dimensional Space
We now extend the concept to a basis made of vectors that are not necessarily orthogonal or unit vectors. Let \( \mathbf{v}_1 \) and \( \mathbf{v}_2 \) be any two non-parallel vectors in the plane.
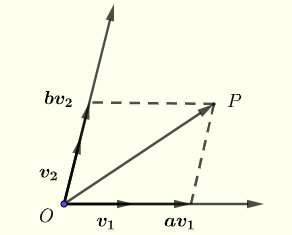
Using a parallelogram, there is a unique way to combine multiples of \( \mathbf{v}_1 \) and \( \mathbf{v}_2 \) to obtain \( \mathbf{OP} \). That is, there is a unique representation
\( \mathbf{OP} = a\,\mathbf{v}_1 + b\,\mathbf{v}_2 \)
The scalars \( a \) and \( b \) are the coordinates of \( \mathbf{OP} \) relative to the basis \( \{ \mathbf{v}_1, \mathbf{v}_2 \} \), provided \( \mathbf{v}_1 \) and \( \mathbf{v}_2 \) are not parallel (i.e., linearly independent). Thus \( \{ \mathbf{v}_1, \mathbf{v}_2 \} \) is a basis for the two-dimensional space.
Generalizing the Definition of a Basis for a Subspace
Let \( S = \{ \mathbf{v}_1, \mathbf{v}_2, \dots, \mathbf{v}_n \} \) be a set of vectors in a vector space \( V \). Then \( S \) is a basis for \( V \) if and only if:
- the vectors in \( S \) are linearly independent;
- the vectors in \( S \) span \( V \).
Dimension of a Vector Space
If \( S = \{ \mathbf{v}_1, \mathbf{v}_2, \dots, \mathbf{v}_n \} \) is a basis for a vector space \( V \), then \( n \) — the number of vectors in the basis — is the dimension of \( V \), denoted \( \dim(V) = n \).
Definition of Coordinates
If \( S = \{ \mathbf{v}_1, \mathbf{v}_2, \dots, \mathbf{v}_n \} \) is a basis for a vector space \( V \), and a vector \( \mathbf{u} \in V \) can be written as
\( \mathbf{u} = r_1 \mathbf{v}_1 + r_2 \mathbf{v}_2 + \dots + r_n \mathbf{v}_n \),
then the column vector
\[ [\mathbf{u}]_S = \begin{bmatrix} r_1 \\ r_2 \\ \vdots \\ r_n \end{bmatrix} \]
is called the coordinate vector of \( \mathbf{u} \) relative to the basis \( S \).
Examples with Solutions
Example 1 — Determine Whether a Set Forms a Basis
Is the set of vectors \( S \) a basis for a subspace of \( \mathbb{R}^3 \)?
\[ S = \left\{ \begin{bmatrix} -1 \\ 1 \\ 0 \end{bmatrix}, \begin{bmatrix} 1 \\ 3 \\ -1 \end{bmatrix}, \begin{bmatrix} -1 \\ 1 \\ 1 \end{bmatrix} \right\} \]
Solution
We first check whether the vectors in \( S \) are linearly independent by solving the vector equation
\[ r_1 \begin{bmatrix} -1 \\ 1 \\ 0 \end{bmatrix} + r_2 \begin{bmatrix} 1 \\ 3 \\ -1 \end{bmatrix} + r_3 \begin{bmatrix} -1 \\ 1 \\ 1 \end{bmatrix} = \begin{bmatrix} 0 \\ 0 \\ 0 \end{bmatrix}. \]
Expressed in matrix form, this homogeneous system is:
\[ \begin{bmatrix} -1 & 1 & -1 \\ 1 & 3 & 1 \\ 0 & -1 & 1 \end{bmatrix} \begin{bmatrix} r_1 \\ r_2 \\ r_3 \end{bmatrix} = \begin{bmatrix} 0 \\ 0 \\ 0 \end{bmatrix}. \quad \text{(I)} \]
The augmented matrix for this system is:
\[ \begin{bmatrix} -1 & 1 & -1 & | & 0 \\ 1 & 3 & 1 & | & 0 \\ 0 & -1 & 1 & | & 0 \end{bmatrix}. \]
We now row-reduce this augmented matrix to row echelon form:
- Step 1. Add row 1 to row 2 (i.e., \( R_2 \leftarrow R_2 + R_1 \)): \[ \begin{bmatrix} -1 & 1 & -1 & | & 0 \\ 0 & 4 & 0 & | & 0 \\ 0 & -1 & 1 & | & 0 \end{bmatrix} \]
- Step 2. Add \( 4 \) times row 3 to row 2 (i.e., \( R_2 \leftarrow R_2 + 4 R_3 \)): \[ \begin{bmatrix} -1 & 1 & -1 & | & 0 \\ 0 & 0 & 4 & | & 0 \\ 0 & -1 & 1 & | & 0 \end{bmatrix} \]
- Step 3. Interchange rows 2 and 3 (i.e., \( R_2 \leftrightarrow R_3 \)): \[ \begin{bmatrix} -1 & 1 & -1 & | & 0 \\ 0 & -1 & 1 & | & 0 \\ 0 & 0 & 4 & | & 0 \end{bmatrix} \]
- Step 4. Multiply row 1 by \( -1 \) and row 2 by \( -1 \): \[ \begin{bmatrix} 1 & -1 & 1 & | & 0 \\ 0 & 1 & -1 & | & 0 \\ 0 & 0 & 4 & | & 0 \end{bmatrix} \]
- Step 5. Multiply row 3 by \( \tfrac{1}{4} \): \[ \begin{bmatrix} 1 & -1 & 1 & | & 0 \\ 0 & 1 & -1 & | & 0 \\ 0 & 0 & 1 & | & 0 \end{bmatrix} \]
Pivots appear in columns 1, 2, and 3. There are no free variables, so the only solution is the trivial one \( r_1 = r_2 = r_3 = 0 \). Hence the vectors in \( S \) are linearly independent.
Now check whether the vectors span \( \mathbb{R}^3 \).
Form the square matrix whose columns are the vectors of \( S \):
\[ M = \begin{bmatrix} -1 & 1 & -1 \\ 1 & 3 & 1 \\ 0 & -1 & 1 \end{bmatrix}. \]
Compute its determinant by cofactor expansion along the first row:
\[ \det(M) = -1 \det\begin{bmatrix} 3 & 1 \\ -1 & 1 \end{bmatrix} - 1 \det\begin{bmatrix} 1 & 1 \\ 0 & 1 \end{bmatrix} + (-1) \det\begin{bmatrix} 1 & 3 \\ 0 & -1 \end{bmatrix} \] \[ = -1(3 + 1) - 1(1 - 0) - 1(-1 - 0) = -4 - 1 + 1 = -4 \neq 0. \]
Since \( \det(M) \neq 0 \), the matrix is invertible, and the columns of \( M \) span \( \mathbb{R}^3 \).
The set \( S \) is both linearly independent and spans \( \mathbb{R}^3 \). Therefore \( S \) is a basis for \( \mathbb{R}^3 \).
Example 2 — Find Coordinate Vectors Relative to a Basis
Given the basis \( S \) of a subspace \( V \) and a vector \( u \in V \):
\[ S = \left\{ \begin{bmatrix} 1 \\ 0 \\ 1 \\ 0 \end{bmatrix}, \begin{bmatrix} 0 \\ 2 \\ 1 \\ 0 \end{bmatrix}, \begin{bmatrix} 1 \\ 1 \\ -1 \\ 1 \end{bmatrix} \right\}, \qquad u = \begin{bmatrix} 4 \\ -3 \\ 0 \\ 1 \end{bmatrix}. \]
(a) What is the dimension of \( V \)? (b) Find the coordinate vector \( [u]_S \).
Solution
(a) The dimension of \( V \) equals the number of vectors in a basis, so \( \dim(V) = 3 \).
(b) Solve \( u = r_1 v_1 + r_2 v_2 + r_3 v_3 \):
\[ \begin{bmatrix} 4 \\ -3 \\ 0 \\ 1 \end{bmatrix} = r_1 \begin{bmatrix} 1 \\ 0 \\ 1 \\ 0 \end{bmatrix} + r_2 \begin{bmatrix} 0 \\ 2 \\ 1 \\ 0 \end{bmatrix} + r_3 \begin{bmatrix} 1 \\ 1 \\ -1 \\ 1 \end{bmatrix}. \]
Augmented matrix:
\[ \begin{bmatrix} 1 & 0 & 1 & | & 4 \\ 0 & 2 & 1 & | & -3 \\ 1 & 1 & -1 & | & 0 \\ 0 & 0 & 1 & | & 1 \end{bmatrix}. \]
Row-reducing gives:
\[ \begin{bmatrix} 1 & 0 & 0 & | & 3 \\ 0 & 1 & 0 & | & -2 \\ 0 & 0 & 1 & | & 1 \\ 0 & 0 & 0 & | & 0 \end{bmatrix}. \]
So \( r_1 = 3 \), \( r_2 = -2 \), \( r_3 = 1 \), and
\[ [u]_S = \begin{bmatrix} 3 \\ -2 \\ 1 \end{bmatrix}. \]
Example 3 — Change of Basis Coordinates
Given the basis \( S_1 \) and coordinate vector \( [u]_{S_1} \):
\[ S_1 = \left\{ \begin{bmatrix} 1 \\ 2 \end{bmatrix}, \begin{bmatrix} -3 \\ 1 \end{bmatrix} \right\}, \qquad [u]_{S_1} = \begin{bmatrix} -1 \\ 2 \end{bmatrix}. \]
Find \( [u]_{S_2} \) relative to the new basis \( S_2 = \left\{ \begin{bmatrix} 0 \\ -1 \end{bmatrix}, \begin{bmatrix} -1 \\ 2 \end{bmatrix} \right\} \).
Solution
First, recover the standard vector representation:
\[ u = -1 \begin{bmatrix} 1 \\ 2 \end{bmatrix} + 2 \begin{bmatrix} -3 \\ 1 \end{bmatrix} = \begin{bmatrix} -1 - 6 \\ -2 + 2 \end{bmatrix} = \begin{bmatrix} -7 \\ 0 \end{bmatrix}. \]
Now solve \( u = r_1 w_1 + r_2 w_2 \) for \( S_2 \):
\[ \begin{bmatrix} -7 \\ 0 \end{bmatrix} = r_1 \begin{bmatrix} 0 \\ -1 \end{bmatrix} + r_2 \begin{bmatrix} -1 \\ 2 \end{bmatrix}. \]
Augmented matrix:
\[ \begin{bmatrix} 0 & -1 & | & -7 \\ -1 & 2 & | & 0 \end{bmatrix}. \]
Row-reducing gives:
\[ \begin{bmatrix} 1 & -2 & | & 0 \\ 0 & 1 & | & 7 \end{bmatrix}. \]
Back-substituting: \( r_2 = 7 \) and \( r_1 = 14 \). Therefore
\[ [u]_{S_2} = \begin{bmatrix} 14 \\ 7 \end{bmatrix}. \]
Example 4 — Find a Basis for a Spanned Subspace
Find a basis for the subspace of \( \mathbb{R}^3 \) spanned by:
\[ \begin{bmatrix} 1 \\ 1 \\ 2 \end{bmatrix}, \; \begin{bmatrix} -1 \\ -2 \\ -7 \end{bmatrix}, \; \begin{bmatrix} 1 \\ 0 \\ -3 \end{bmatrix}, \; \begin{bmatrix} 2 \\ 0 \\ 6 \end{bmatrix}. \]
Solution
Place the vectors as columns of a matrix and row-reduce:
\[ A = \begin{bmatrix} 1 & -1 & 1 & 2 \\ 1 & -2 & 0 & 0 \\ 2 & -7 & -3 & 6 \end{bmatrix} \xrightarrow{\;\text{RREF}\;}\; \begin{bmatrix} 1 & 0 & 2 & 0 \\ 0 & 1 & 1 & 0 \\ 0 & 0 & 0 & 1 \end{bmatrix}. \]
Pivot columns are 1, 2, and 4. The corresponding columns of the original matrix form a basis for the column space:
\[ \left\{ \begin{bmatrix} 1 \\ 1 \\ 2 \end{bmatrix}, \begin{bmatrix} -1 \\ -2 \\ -7 \end{bmatrix}, \begin{bmatrix} 2 \\ 0 \\ 6 \end{bmatrix} \right\}. \]
Note: the dimension of the column space equals the number of pivots in the row echelon form.
Questions with Solutions
Question 1 — Is It a Basis?
Is \( S = \left\{ \begin{bmatrix} 1 \\ 0 \end{bmatrix}, \begin{bmatrix} 0 \\ 1 \end{bmatrix}, \begin{bmatrix} 1 \\ 1 \end{bmatrix} \right\} \) a basis for \( \mathbb{R}^2 \)? Justify your answer.
Solution
No. A basis for \( \mathbb{R}^2 \) must have exactly 2 vectors. The set \( S \) has 3, so it cannot be a basis. In fact, the three vectors are linearly dependent: \( (1,1) = (1,0) + (0,1) \).
Question 2 — Find Coordinates Relative to a Basis
Find the coordinate vector of \( u = \begin{bmatrix} 5 \\ 6 \end{bmatrix} \) relative to \( S = \left\{ \begin{bmatrix} 1 \\ 1 \end{bmatrix}, \begin{bmatrix} 1 \\ -1 \end{bmatrix} \right\} \).
Solution
Solve \( r_1 (1,1) + r_2 (1,-1) = (5,6) \):
\[ \begin{cases} r_1 + r_2 = 5 \\ r_1 - r_2 = 6 \end{cases} \]
Adding: \( 2r_1 = 11 \Rightarrow r_1 = \tfrac{11}{2} \). Subtracting: \( 2r_2 = -1 \Rightarrow r_2 = -\tfrac{1}{2} \).
\[ [u]_S = \begin{bmatrix} 11/2 \\ -1/2 \end{bmatrix}. \]
Question 3 — Dimension of a Column Space
Find a basis for the column space of \( A = \begin{bmatrix} 1 & 2 & 0 \\ 0 & 1 & 1 \\ 1 & 3 & 1 \end{bmatrix} \), and state its dimension.
Solution
Row-reduce \( A \):
\[ A \xrightarrow{\;\text{RREF}\;}\; \begin{bmatrix} 1 & 0 & -2 \\ 0 & 1 & 1 \\ 0 & 0 & 0 \end{bmatrix}. \]
Pivot columns are 1 and 2. A basis for the column space is:
\[ \left\{ \begin{bmatrix} 1 \\ 0 \\ 1 \end{bmatrix}, \begin{bmatrix} 2 \\ 1 \\ 3 \end{bmatrix} \right\}. \]
The dimension of the column space (the rank of \( A \)) is \( 2 \).
More References and Links
- Linear Algebra – Questions with Solutions
- Linearly Independent and Dependent Vectors
- Linear Combinations and Span of Vectors
- Linear Algebra and its Applications – 5th Edition – David C. Lay, Steven R. Lay, Judi J. McDonald
- Elementary Linear Algebra – 7th Edition – Howard Anton and Chris Rorres